Resolving the Missing Joint Error in turtlebot3_manipulation with ROS2

When running the turtlebot3_manipulation package in ROS2, an error may arise indicating that a joint is not found:

Specifically, the error message can prevent the proper operation of the TurtleBot3 manipulator. This issue can be resolved by editing the URDF file associated with the TurtleBot3 manipulation description.

Continue reading →
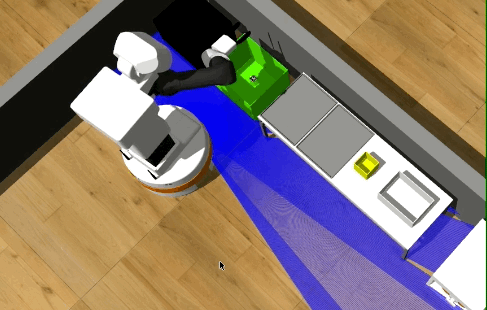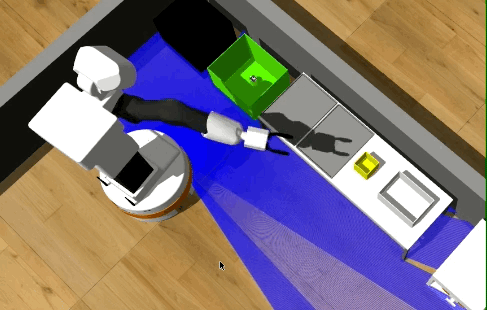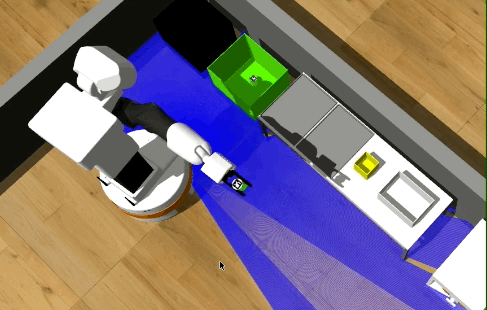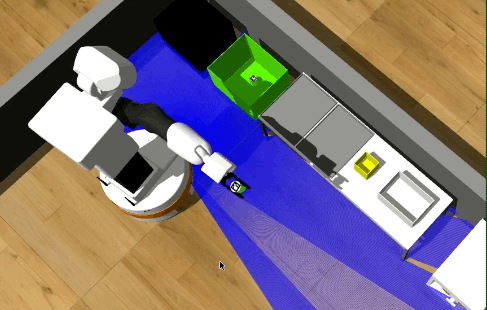
Spawn Objects in Gazebo of ROS Kinetic & Melodic (Python 2.7)

Spawn objects in the TIAGO’s gripper

Sometimes we need to add new objects to Gazebo to build a dynamic environment, particularly in some manipulation tasks. Suppose we test if the robot can pick up items from the floor. Thus, we may need a program to spawn models in a random position in the environment to verify our manipulation algorithms’ robustness. Like the top picture, a new cylinder is created in TIAGO’s gripper. Then TIAGO can deliver the cylinder to a free container.

Continue reading →

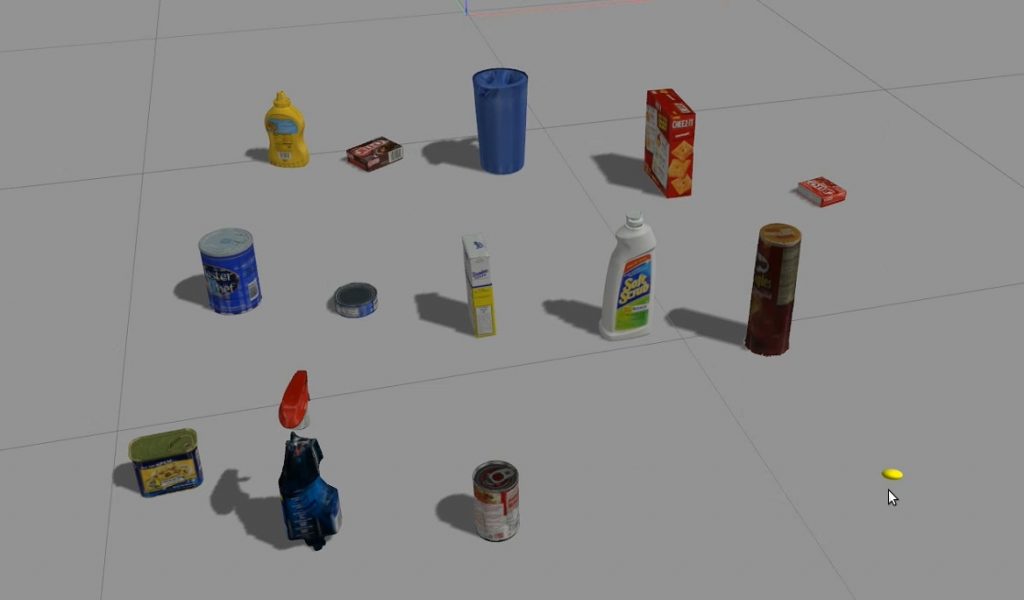
Use YCB Dataset Objects in Gazebo

Although YCB Benchmarks has provided a series of mesh files, they still cannot be used directly in Gazebo because of the missing some of the physical properties.

I made SDF models for most YCB objects that can be used directly in Gazebo, and provided them with the following optimizations:

  1. Stable friction parameters.
  2. Enhanced lighting.
  3. HD textures.
YCB objects
Continue reading →